Our long-term goal is a general-purpose robot that can work alongside people in any environment. We are not there yet, and we believe the way to get there is to build robots that truly work in specific, real-world settings first. So we advance robotics in two directions: (1) enabling technology, the methods that will eventually lead to general robots, and (2) application, specific use cases where robots can make a difference today. Our current applications are surgical operation, lab automation, and hotel operation.
Category 1. Enabling Technology
One direction is enabling technology side. This includes how we can build and control robots more systematically and efficiently. This means that we focus on methods rather than specific robots. From this perspective, we build frameworks that design robots with minimal human effort, using computational approaches including AI, optimization, and simulation.
1.1. Computational Robot Co-Design
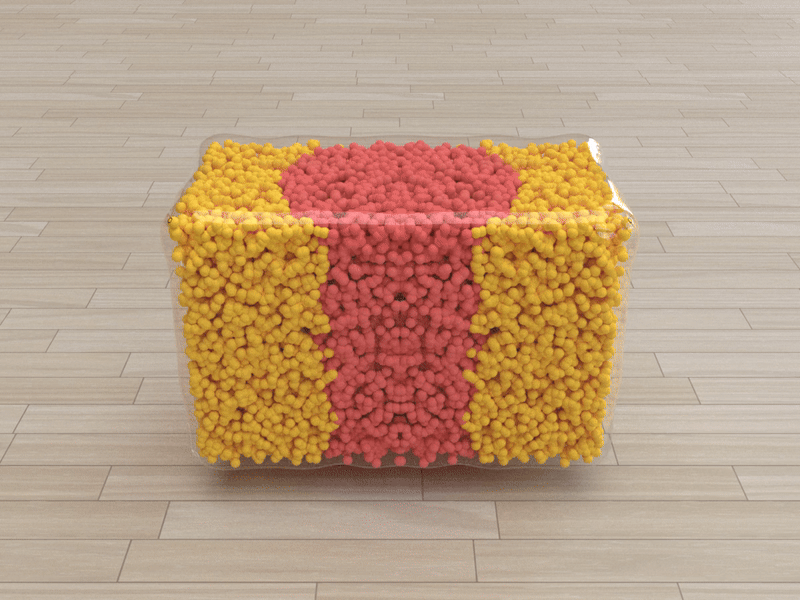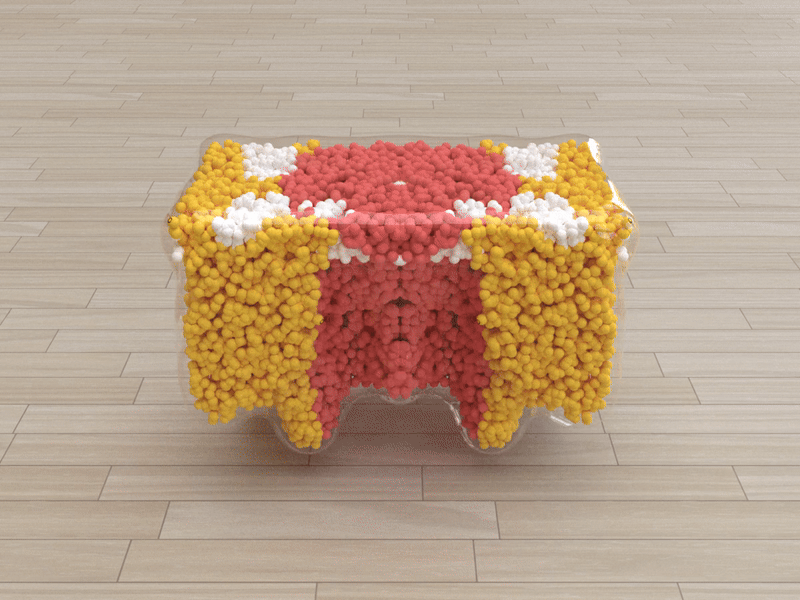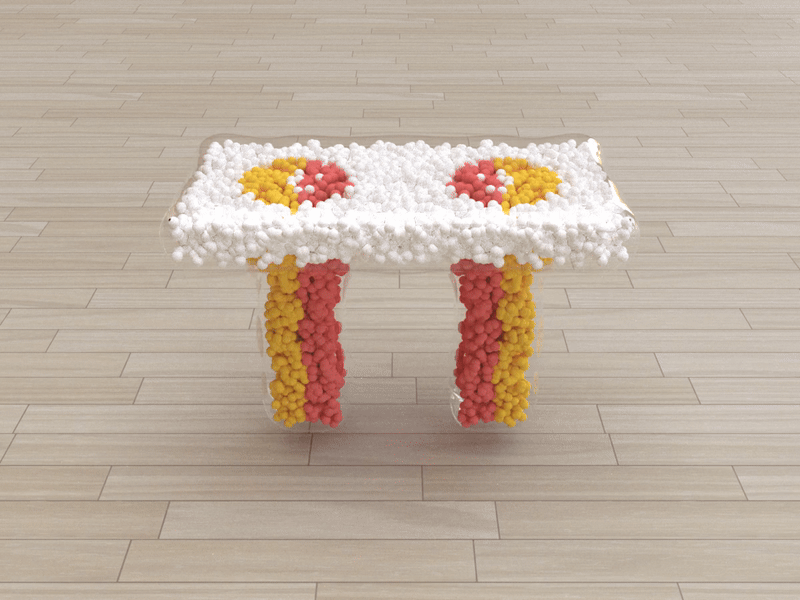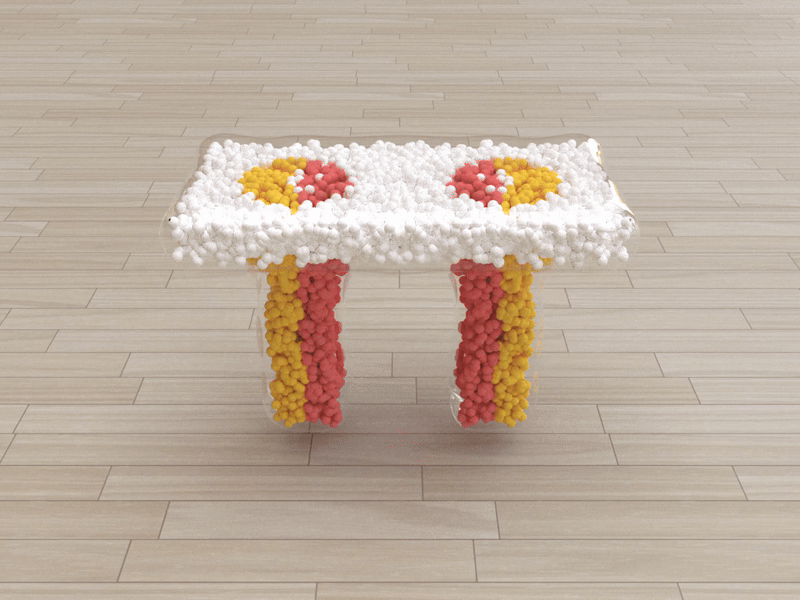
Computational Robot Co-Design
We develop AI-driven frameworks for robot body & controller co-design, integrating generative models, physics simulation, and optimization. This approach enables scalable, task-specific robots such as agile legged systems or modular manipulators.
Learn More1.2. Brain-Inspired Physical AI
Brain-Inspired Physical AI
We take inspiration from how the human brain perceives, plans, and controls the body to build Physical AI that learns efficiently, adapts quickly, and acts reliably in the physical world.
Learn MoreCategory 2. Application
Another direction is application side. This includes how we can apply robotics to real-world problems, especially in human-centered domains. This means that we focus on specific robots rather than methods. From this perspective, we build robots that assist people in daily life and at work, such as robotic hands and Physical AI for surgery, lab automation, and hotels.
2.1. Robotic Hands
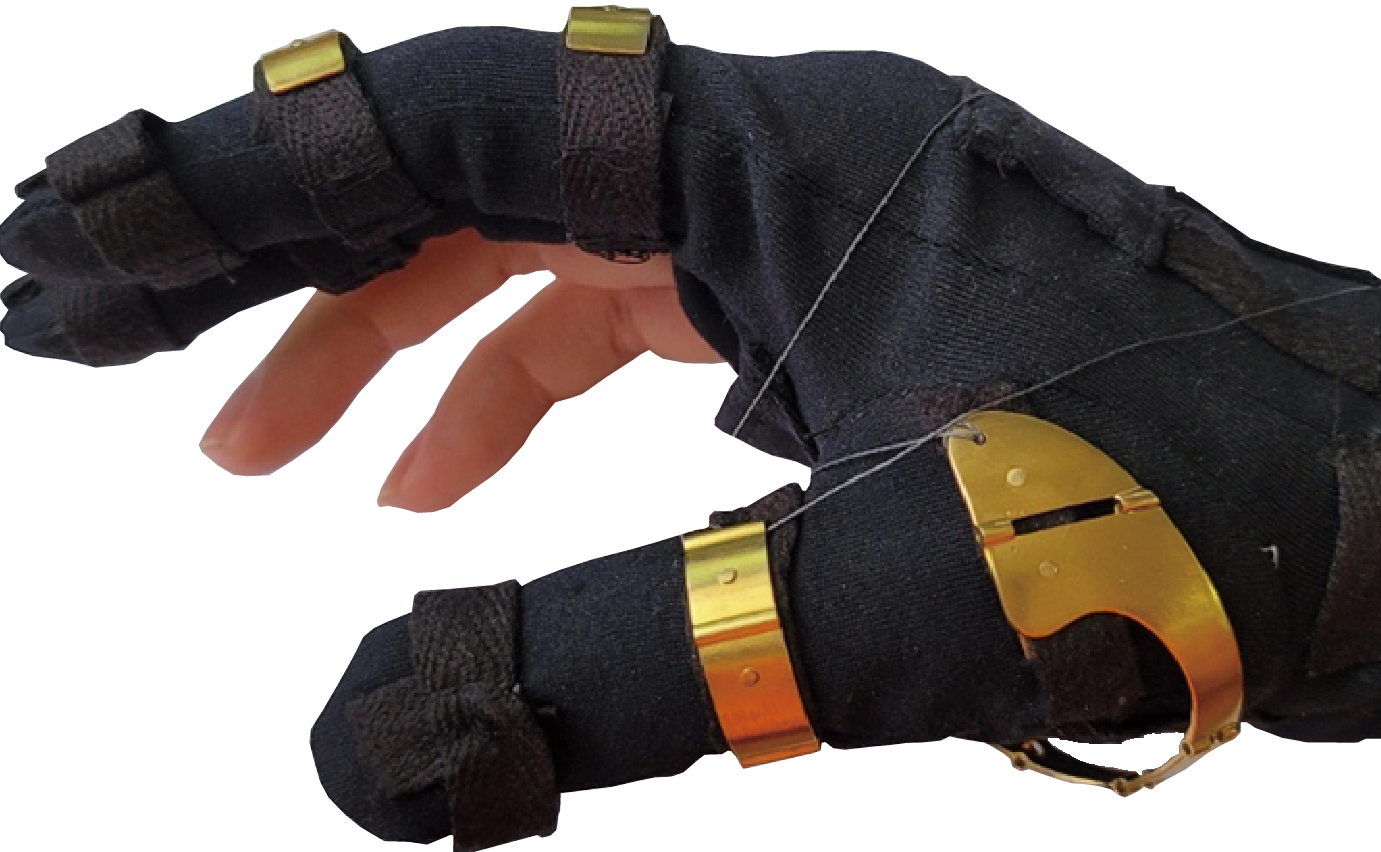
Wearable Robots, Prosthetics & Robot Hands
We design tendon-driven, under-actuated hands, from hand-wearable robots and prosthetic hands that assist people, to robot hands for humanoids and robot arms.
Learn More2.2. Physical AI (VLA)
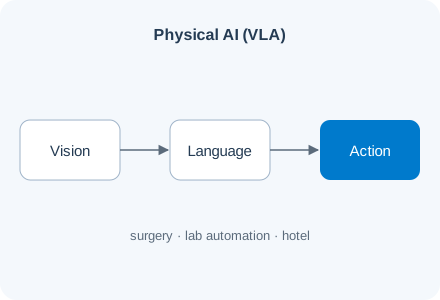
Physical AI for Real-World Operation
We build Vision-Language-Action (VLA) based Physical AI for specific real-world use cases rather than general tasks: surgical assistance, lab automation, and hotel room housekeeping.
Learn MoreOngoing Projects
| Project | Period |
|---|---|
| MAESTRO: Multimodal Action Data Factory for Embodied Surgical and Therapeutic Robotic Operation (체화지능형 의료로봇 구현을 위한 멀티모달 Action Data Factory 원천기술 개발) |
2026.07 – 2030.06 |
| AI-based Design Optimization of Task-Specific Robot Hands for Humanoids and Robot Arms (휴머노이드 및 로봇팔을 위한 작업특화 로봇손의 AI 기반 로봇 설계 최적화) |
2026.03 – 2028.03 |
| TWIN-STAY: Adaptive Digital Twin and Robot–Space Co-design for Autonomous Hotel Operation (호텔 객실 자동화를 위한 적응형 디지털 트윈 및 로봇-공간 공동설계 원천기술 개발) |
2027.01 – 2027.12 |